Kastalia Knowledge Management System · Glasperlenspiel template · knot 4305
Six sensors, one skeleton
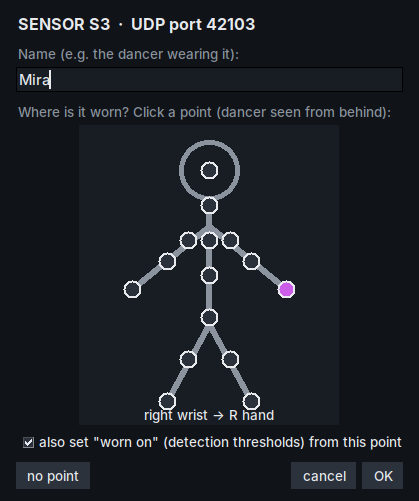
Two hands, two legs, torso, head.
Each sensor reports its orientation (roll, pitch, yaw), its rotation speed and its acceleration — at rest it feels gravity, 1 g pointing up.
Today we only need the first: orientation.
Ancestors (1 superordinated path)
root/
baumhaus.digital/
Klasse Leben/
WiSeAE56/
On Tracking : Dancing Piano II./
Roll, Pitch, Yaw/
Six sensors, one skeleton