no sessions catalogued here yet
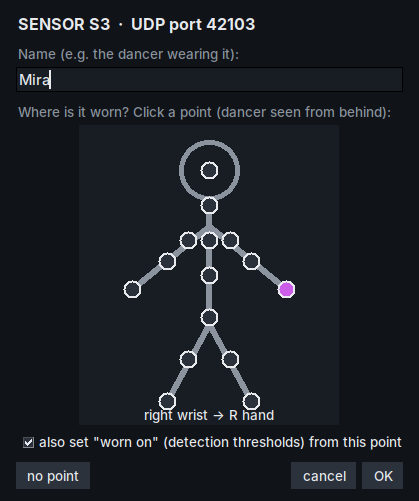
Six sensors, one skeleton
12.11.2026 · AE561112
Two hands, two legs, torso, head.
Each sensor reports its orientation (roll, pitch, yaw), its rotation speed and its acceleration — at rest it feels gravity, 1 g pointing up.
Today we only need the first: orientation.
