no sessions catalogued here yet
The body is the coordinate system
12.11.2026 · AE561112
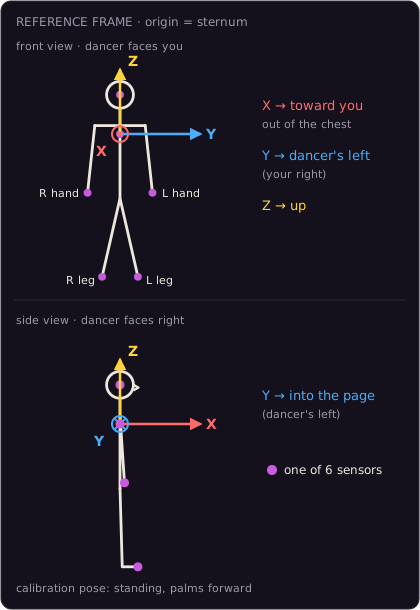
Origin: the sternum.
Calibration pose: standing straight, arms hanging, palms turned forward.
X points forward, out of the chest. Y points to the dancer's left. Z points up.
Like an aeroplane flying forward: nose, left wing, up.
Calibrate = declare this pose to be zero.
